Keep power, feedback, I/O and data reliable through repeated motion.
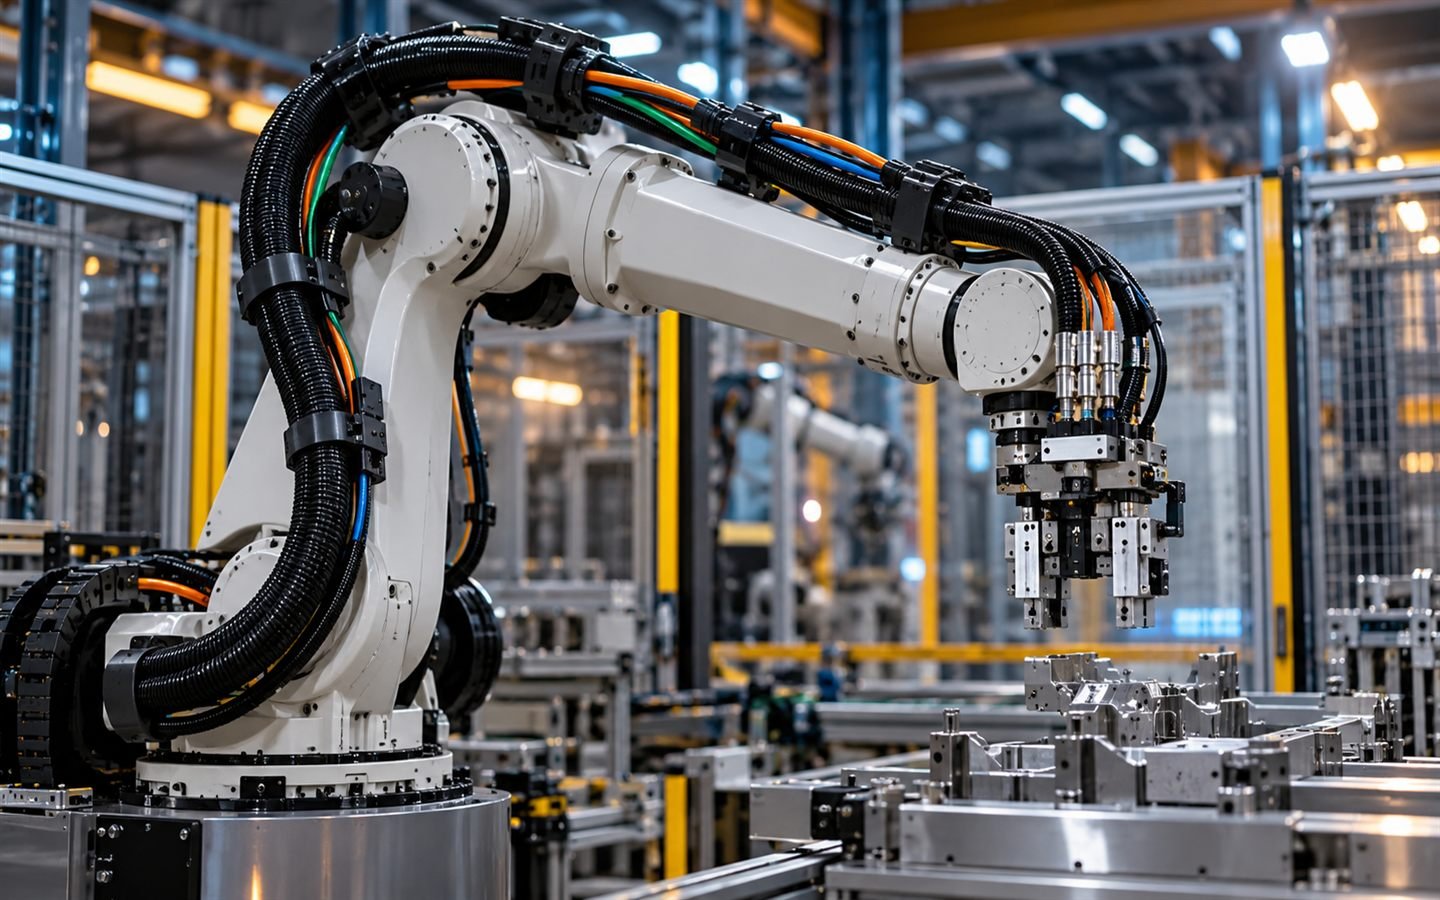
Robot dress packs and moving axes place connectors and cables under torsion, bending and acceleration. The connection plan must combine compact interfaces with controlled strain relief, service loops and cable constructions selected for the actual motion profile.
What the system must connect
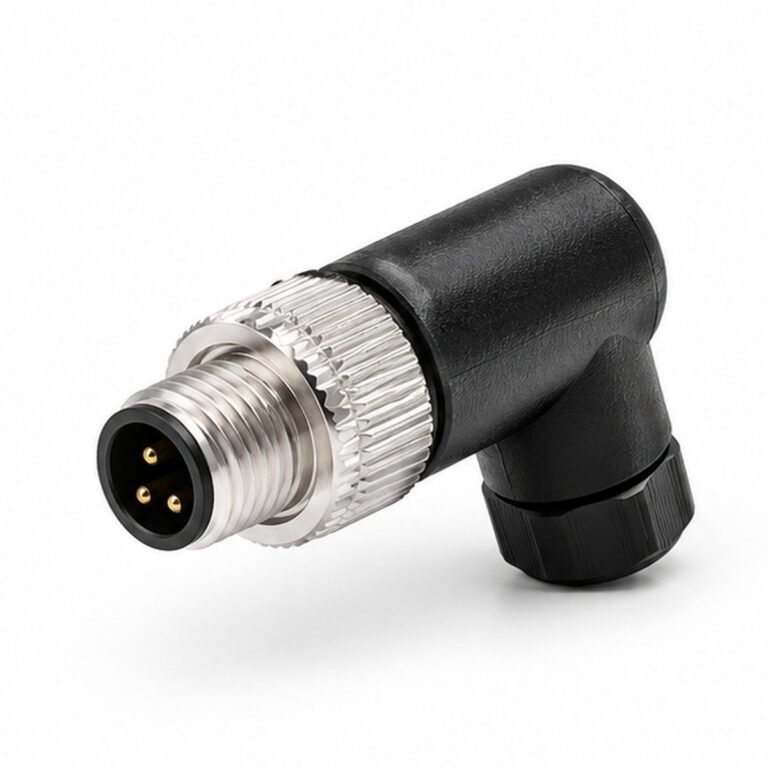
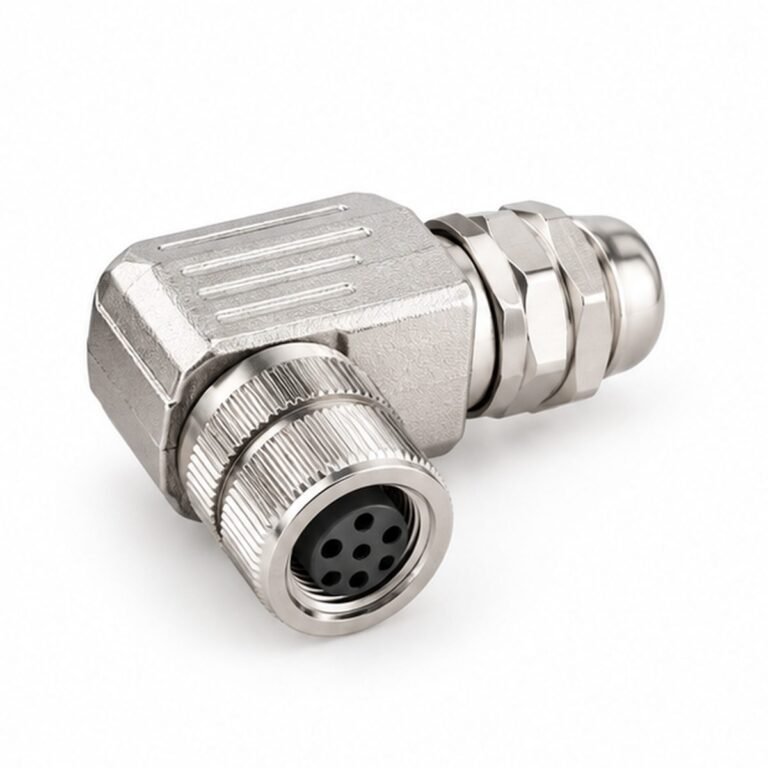
- M8 and M12 connectors for end-effector sensors, valves and tool changers.
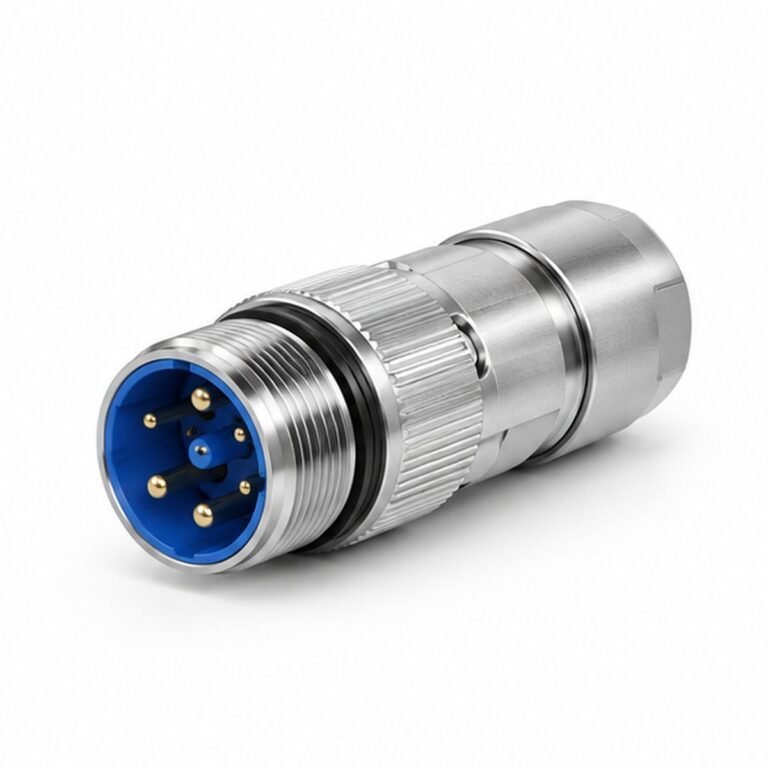
- M23 signal and power interfaces for servo axes and larger motion equipment.
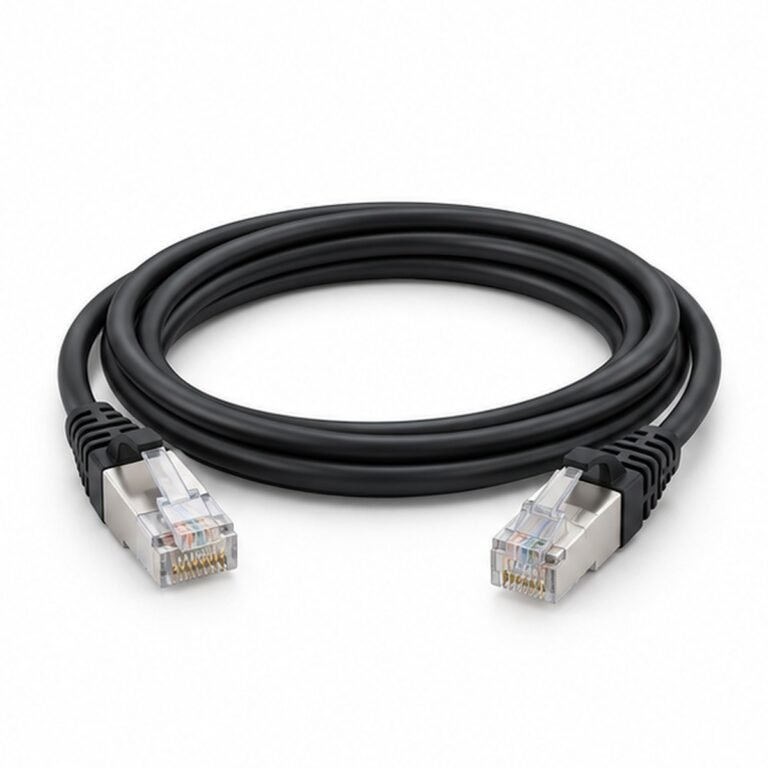
- High-flex GigE and camera I/O assemblies for robot-mounted inspection.
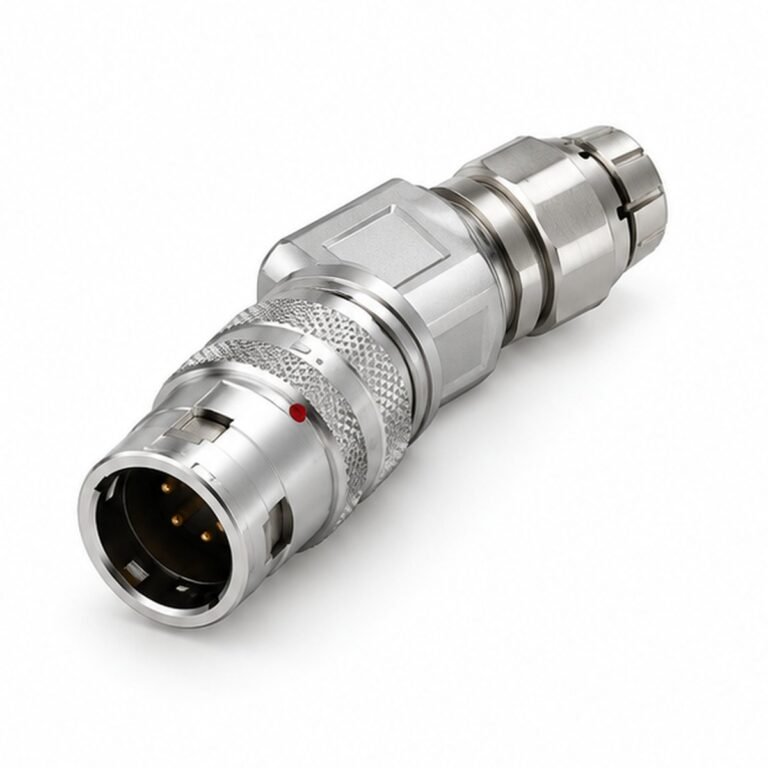
- Right-angle connector bodies where wrist and joint clearance is limited.
- Rugged push-pull interfaces for frequently serviced tools and modules.
Define before release
- Define axis travel, torsion, bend radius and cycles per minute.
- Separate fixed, flexing and torsional cable zones.
- Confirm current, signal integrity, shield path and connector retention.
- Validate routing on the robot before releasing production length.
Compatible LMConn products
Recommended product directions
These products are practical starting points for this application. Final pin count, coding, gender, cable and electrical ratings must be confirmed on the approved drawing.